Capturing indoor scenes
Indoor laps through Levine and Moore pair color frames with aligned depth images, camera intrinsics, timestamps, and robot poses. These recordings provide appearance and geometry inputs for scene reconstruction.
3D vision · Robotics
RGB-D scene reconstruction
Reconstructing indoor environments with 3D Gaussian Splatting from RGB-D lap recordings, combining calibrated images, depth, and robot poses with dataset filtering and reconstruction inspection.
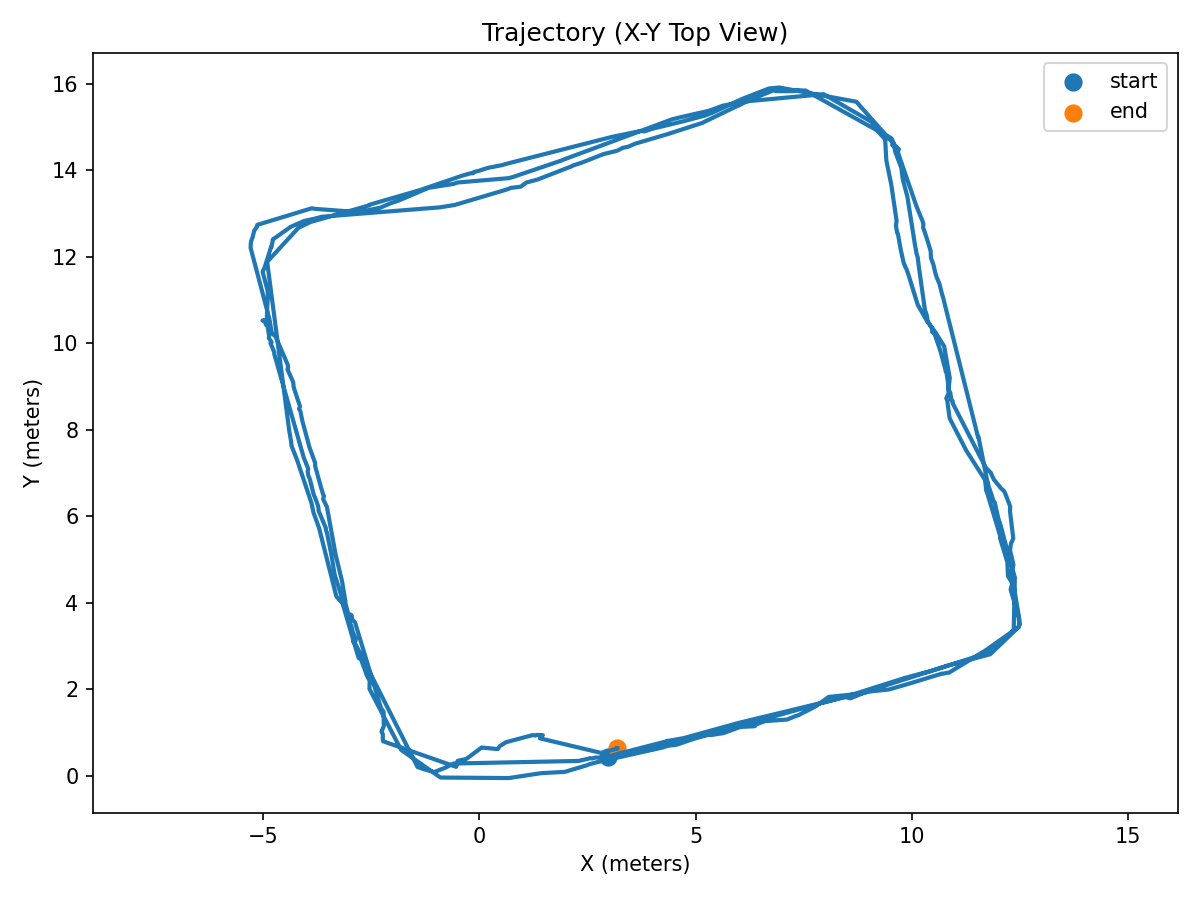
Indoor laps through Levine and Moore pair color frames with aligned depth images, camera intrinsics, timestamps, and robot poses. These recordings provide appearance and geometry inputs for scene reconstruction.
Associate captured frames with ROS poses in the map frame. Filtered datasets retain valid image, depth, and pose samples and record skipped transform failures; trajectory plots help inspect spatial coverage across repeated laps.
Saved Gaussian models at 7,000 and 30,000 training iterations preserve position, scale, rotation, opacity, and appearance parameters. These outputs capture the reconstructed scene as a collection of 3D Gaussians.
An Open3D viewer loads reconstruction outputs for geometric inspection. Recorded trajectories and RGB inputs provide context for reviewing the captured environment and reconstruction.
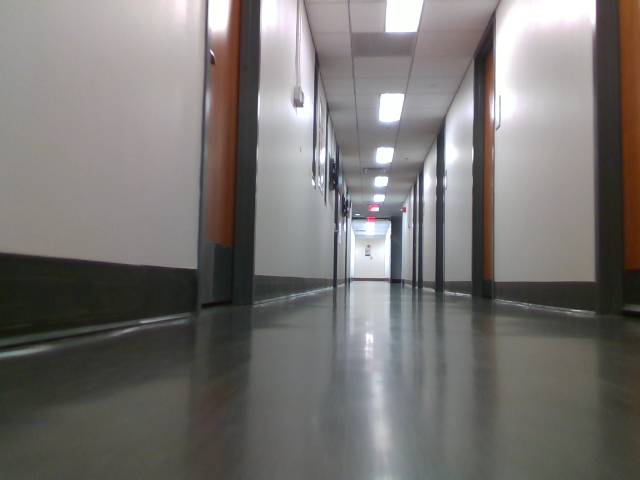
RGB input from a Levine lap capture.
Rendered scene and reconstruction walkthrough — coming soon.