Caster vision
Track visual features from two cameras to estimate caster motion. The model separates shared rolling motion from independent shell rotation, connecting image measurements with the caster’s mechanics.
ModLab · University of Pennsylvania
Holonomic mobile robotics
Connecting caster design, visual perception, and feedback control for a holonomic mobile robot. The work spans camera-based caster motion estimation, RGB-D mapping and localization, and motor control.
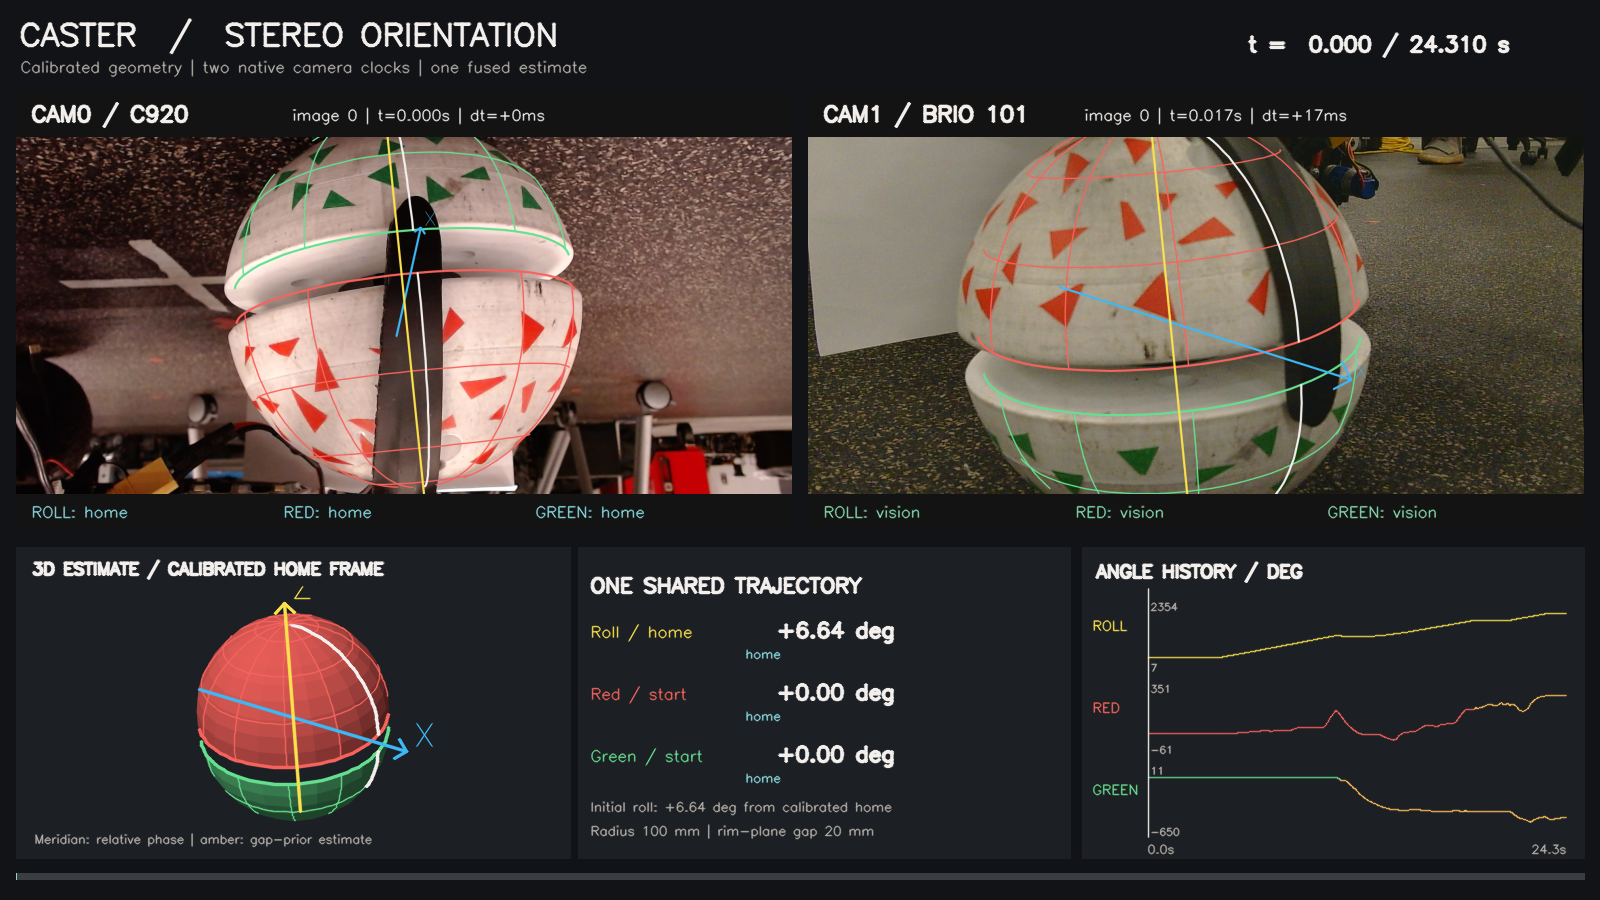
Track visual features from two cameras to estimate caster motion. The model separates shared rolling motion from independent shell rotation, connecting image measurements with the caster’s mechanics.
Use a RealSense D455 with RTAB-Map for RGB-D mapping and localization against saved maps. Wheel odometry and IMU measurements feed an extended Kalman filter to support robot state estimation.
A Jacobian-based ROS 2 controller translates robot motion commands into drive-wheel and turret commands. ESP32 firmware combines feed-forward terms with PID feedback, with motor response measurements supporting controller tuning.
Investigate a split spherical support caster with shared roll and independently rotating hemispheres. Compare its motion with conventional swivel casters through repeatable trajectories and measurements of alignment, slip, and tracking error. These experiments are ongoing.
The latest integrated localization and control setup awaits hardware validation.
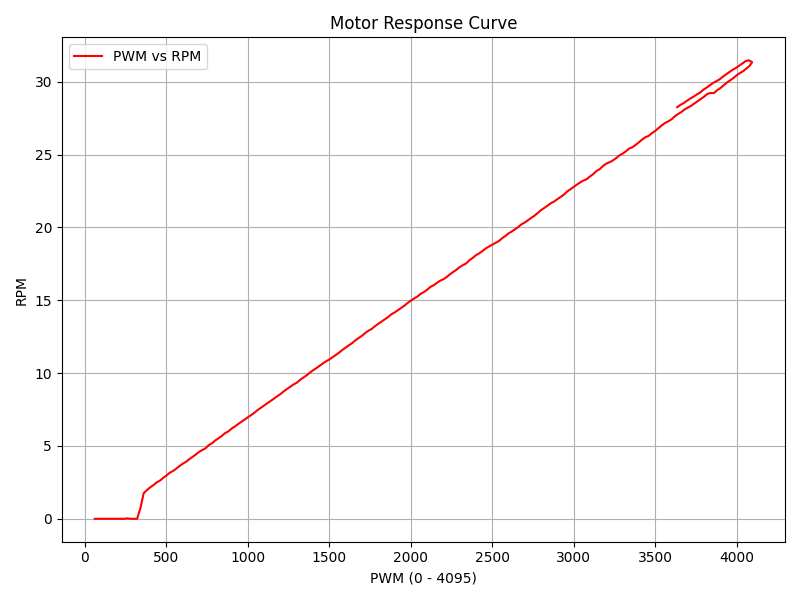
Recorded response for inspecting and tuning motor control.
Map and localization visualization — coming soon.